I am a Ph.D. candidate in Mechanical Engineering at MIT, working in the Biomimetic Robotics Lab. My research focuses on robot learning and reinforcement learning for humanoid robots, with an emphasis on dexterous manipulation and whole-body control, and on combining model-based optimization with learning-based control. I develop MPC- and RL-based controllers for the MIT Humanoid.
In summer 2026, I was a Reinforcement Learning / Robotics Controls Intern at Tesla, where I developed and evaluated reinforcement learning and control algorithms for the Optimus humanoid robot.
Before MIT, I received my M.Sc. in Robotics, Systems and Control from ETH Zürich, where I worked at the Robotic Systems Lab on learning human-robot handover skills from human demonstrations with deep reinforcement learning. I received my B.S. in Mechanical and Aerospace Engineering (minor in Mathematics) from Seoul National University, where I worked on autonomous drone control and visual odometry for unmanned delivery.
News
Publications
For a complete and current record, please visit my Google Scholar profile.
 | Learning Reactive Dexterous Grasping via Hierarchical Task-Space RL Planning and Joint-Space QP ControlHo Jae Lee, Yonghyeon Lee, Alexander Alexiev, Tzu-Yuan Lin, Se Hwan Jeon, Sangbae KimIEEE Transactions on Robotics (under review), 2026 |
 | Point2Pose: Occlusion-Recovering 6D Pose Tracking and 3D Reconstruction for Multiple Unknown Objects via 2D Point TrackersTzu-Yuan Lin, Ho Jae Lee, Kevin Doherty, Yonghyeon Lee, Sangbae KimEuropean Conference on Computer Vision (ECCV), 2026 |
 | Residual MPC: Blending Reinforcement Learning with GPU-Parallelized Model Predictive ControlSe Hwan Jeon, Ho Jae Lee, Seungwoo Hong, Sangbae KimIEEE Transactions on Robotics (T-RO), 2026 |
 | Learning Humanoid Arm Motion via Centroidal Momentum Regularized Multi-Agent Reinforcement LearningHo Jae Lee, Se Hwan Jeon, Sangbae KimIEEE Robotics and Automation Letters (RA-L), 2025 |
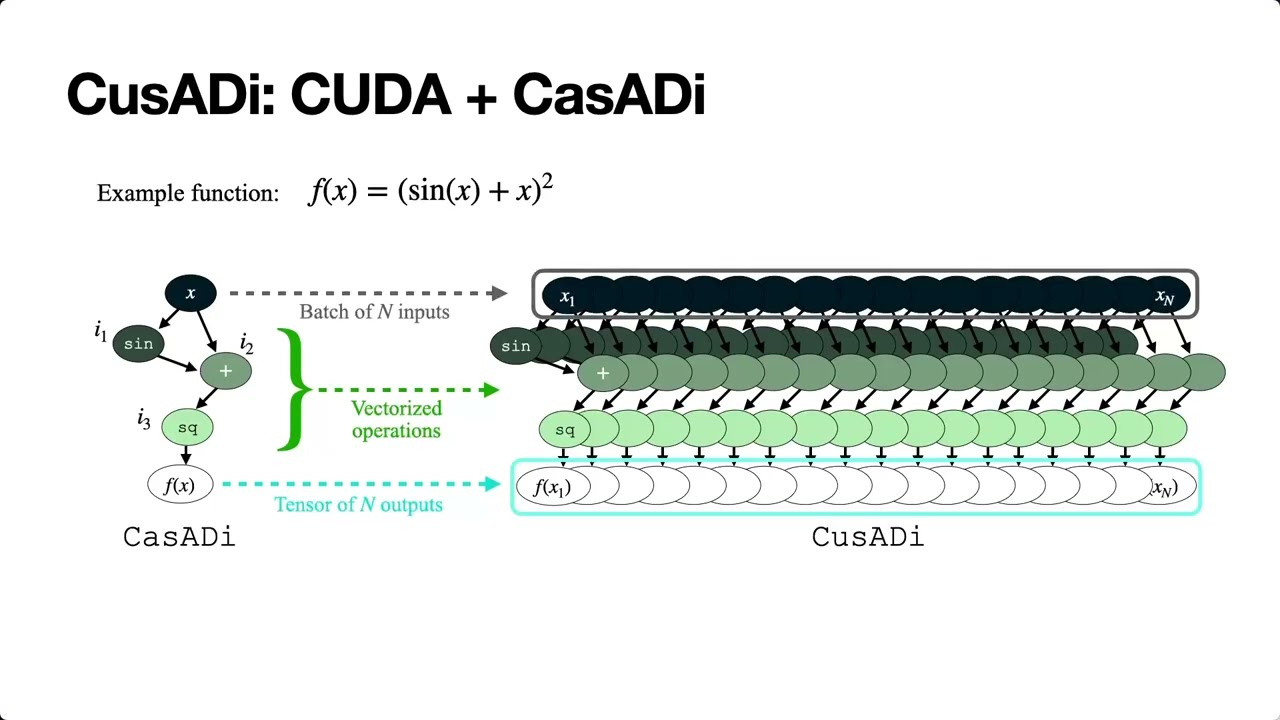 | CusADi: A GPU Parallelization Framework for Symbolic Expressions and Optimal ControlSe Hwan Jeon, Seungwoo Hong, Ho Jae Lee, Charles Khazoom, Sangbae KimIEEE Robotics and Automation Letters (RA-L), 2024 |
 | Integrating Model-Based Footstep Planning with Model-Free Reinforcement Learning for Dynamic Legged LocomotionHo Jae Lee, Seungwoo Hong, Sangbae KimIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024 |
